Hello, I'm Boxuan Ye

You can also call me Stephen if you wish

I study robotics and machine learning at Imperial College London. My work spans quadrotor navigation and recovery, physics-constrained wildfire forecasting, teleoperation, and visual perception for manipulation.

Research & Experience

Robotics · AI · Design Engineering

At Imperial, I develop TRUCE with Dr David Boyle for quadrotor navigation. Since July 2026, I have also worked with Junyi Geng at Penn State on UAV teleoperation and robotic manipulation, and Yiwei Lyu at Texas A&M on wildfire prediction. Earlier research placements at Midea Group and KUKA Robotics focused on humanoid teleoperation, visual perception and manipulation.

  • 🛸 TRUCE quadrotor navigation · submitted to ICRA 2027
  • 🤖 UAV and humanoid teleoperation · robotic manipulation
  • 👁️ Physics-constrained wildfire forecasting · 6D pose estimation

Interfaces

Soft technology & calm tools

I’m interested in how technical systems can feel gentle—how robotics, sensing, and datasets can be shaped as quiet, legible tools rather than noisy complexity. My work often focuses on interaction behaviours: micro-feedback, spatial clarity, and the visual organisation of diagrams and control surfaces.

I prototype with a mixture of embedded controllers, RGB-D cameras, motion sensors, and computational pipelines, supported by clean editorial UI layers for debugging, teleoperation, and documentation.
Python
C++
PyTorch
OpenCV
Open3D
ROS / ROS2
MuJoCo
Isaac Gym
Blender
Fusion 360

Projects

Selected works & experiments

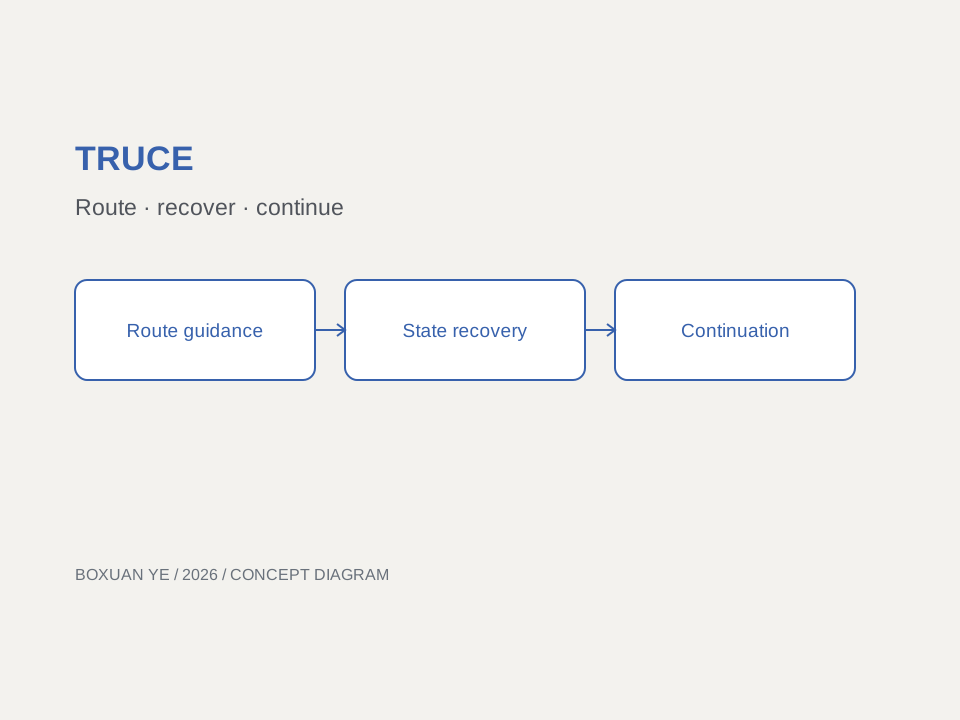
TRUCE: Route-Guided Recovery with Predictive Continuation for Quadrotor Navigation
Robotics · 2026

Submitted to ICRA 2027

TRUCE: Route-Guided Recovery with Predictive Continuation for Quadrotor Navigation

Persistent route guidance, recovery from measured vehicle state, and predictive continuation checks for quadrotor navigation.

View Project
Machine Learning · 2026

Research in progress

Physics-Constrained Wildfire Spread and Fireline Prediction

Learned spread-rate corrections and differentiable anisotropic Eikonal propagation for fireline and arrival-time forecasting.

View Project
Robotics · 2026

Research in progress

UAV Teleoperation and Robotic Manipulation

Operator viewpoints, camera configuration, robotic-arm control and simulation for teleoperation experiments.

View Project
Mixed-Reality Humanoid Robot Teleoperation
Robotics · 2025

Project completed

Mixed-Reality Humanoid Robot Teleoperation

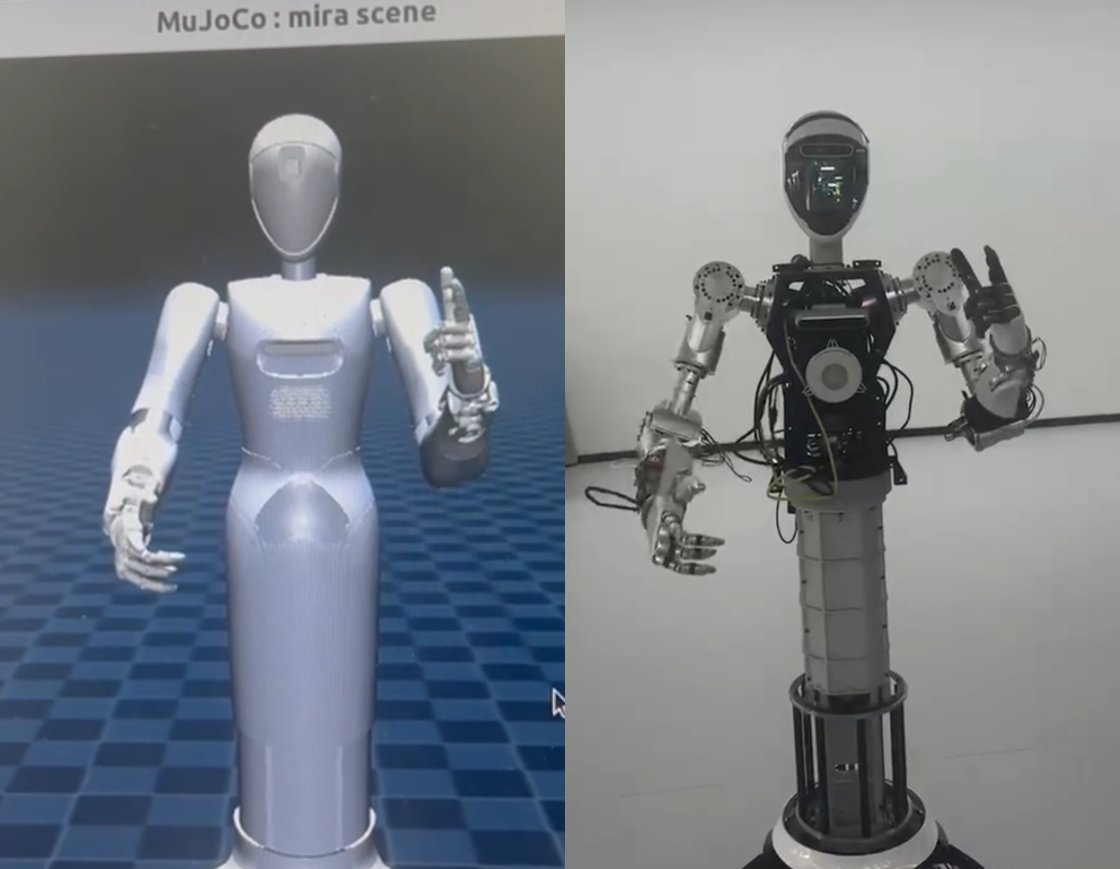
Vision Pro humanoid teleoperation with spatial anchoring, hand/object tracking, streaming and demonstration recording.

View Project

Publications

Published work & submitted manuscript

Submitted to ICRA 2027

  • TRUCE: Route-Guided Recovery with Predictive Continuation for Quadrotor Navigation
  • B. Ye and D. Boyle
  • Project details

Expert Systems with Applications · 332, 133619 · online 2026; issue 2027

  • Real-Gen: Real-Scene-Grounded Generative Augmentation for 6D Object Pose Estimation
  • P. Hou, Y. Zhang and B. Ye

IEEE Robotics and Automation Letters · 11(5), 5454–5461 · 2026

  • Bridging the Depth Gap: Adaptive Scene-Instance Alignment for Training-Free Depth Refinement in Robotic Manipulation Scenes
  • P. Hou, Y. Zhang, B. Ye and Y. Wu
  • DOI

Engineering Applications of Artificial Intelligence · 155, 110890 · 2025

  • A lightweight network for category-level open-vocabulary object pose estimation with enhanced cross implicit space transformation
  • P. Hou, Y. Zhang, W. Zhou, B. Ye and Y. Wu
  • DOI

Education Background

Design Engineering at Imperial

My four-year integrated degree combines undergraduate and master’s study, with coursework in machine learning, robotics, computing, data science, electronics and finite element analysis.

2023 - 2027

MEng Design Engineering · First Class (Expected)

Four-year integrated Bachelor’s and Master’s degree

Imperial College London · Dyson School of Design Engineering

Research Interests

A living archive

I maintain a small archive of experiments, diagrams, code notes, dataset runs, and speculative sketches—updated whenever a result feels worth capturing.

  • 🛸 Reliable aerial navigation, recovery and motion planning
  • 🧠 Robot learning, teleoperation and embodied intelligence
  • 👁️ Open-vocabulary perception & 6D pose estimation
  • 🛰️ Physics-constrained learning and connectome-inspired control

Beyond Work

Music & inspirations

Band & production

  • Bassist in a Chinese rock band and a JPOP band
  • Write songs and basslines with performance 10+

Practice playlists

  • Vulfpeck — Beastly
  • Stevie Wonder — Sir Duke

Recent listens

  • Radiohead · in Rainbows
  • Deca Joins · 浴室