Overview
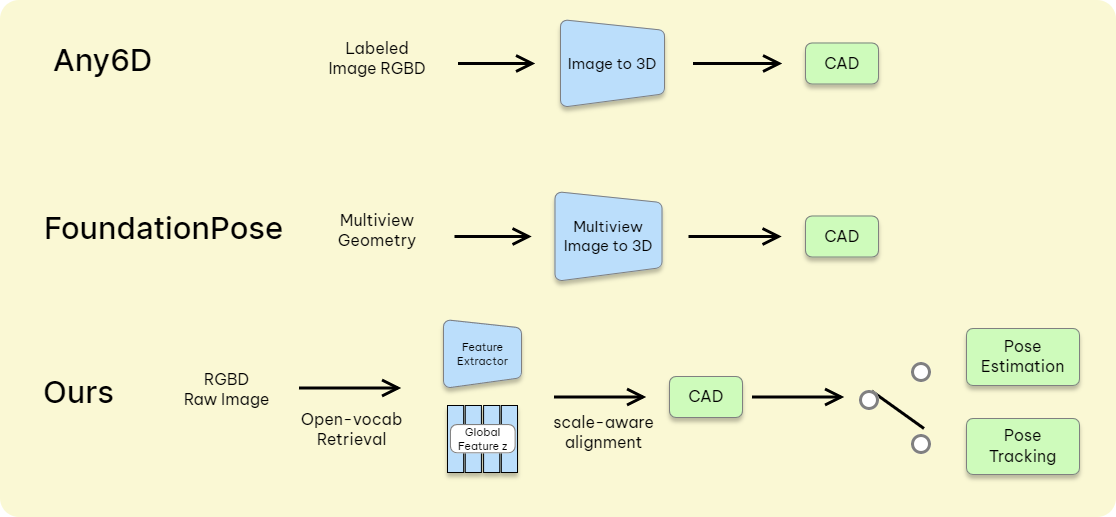
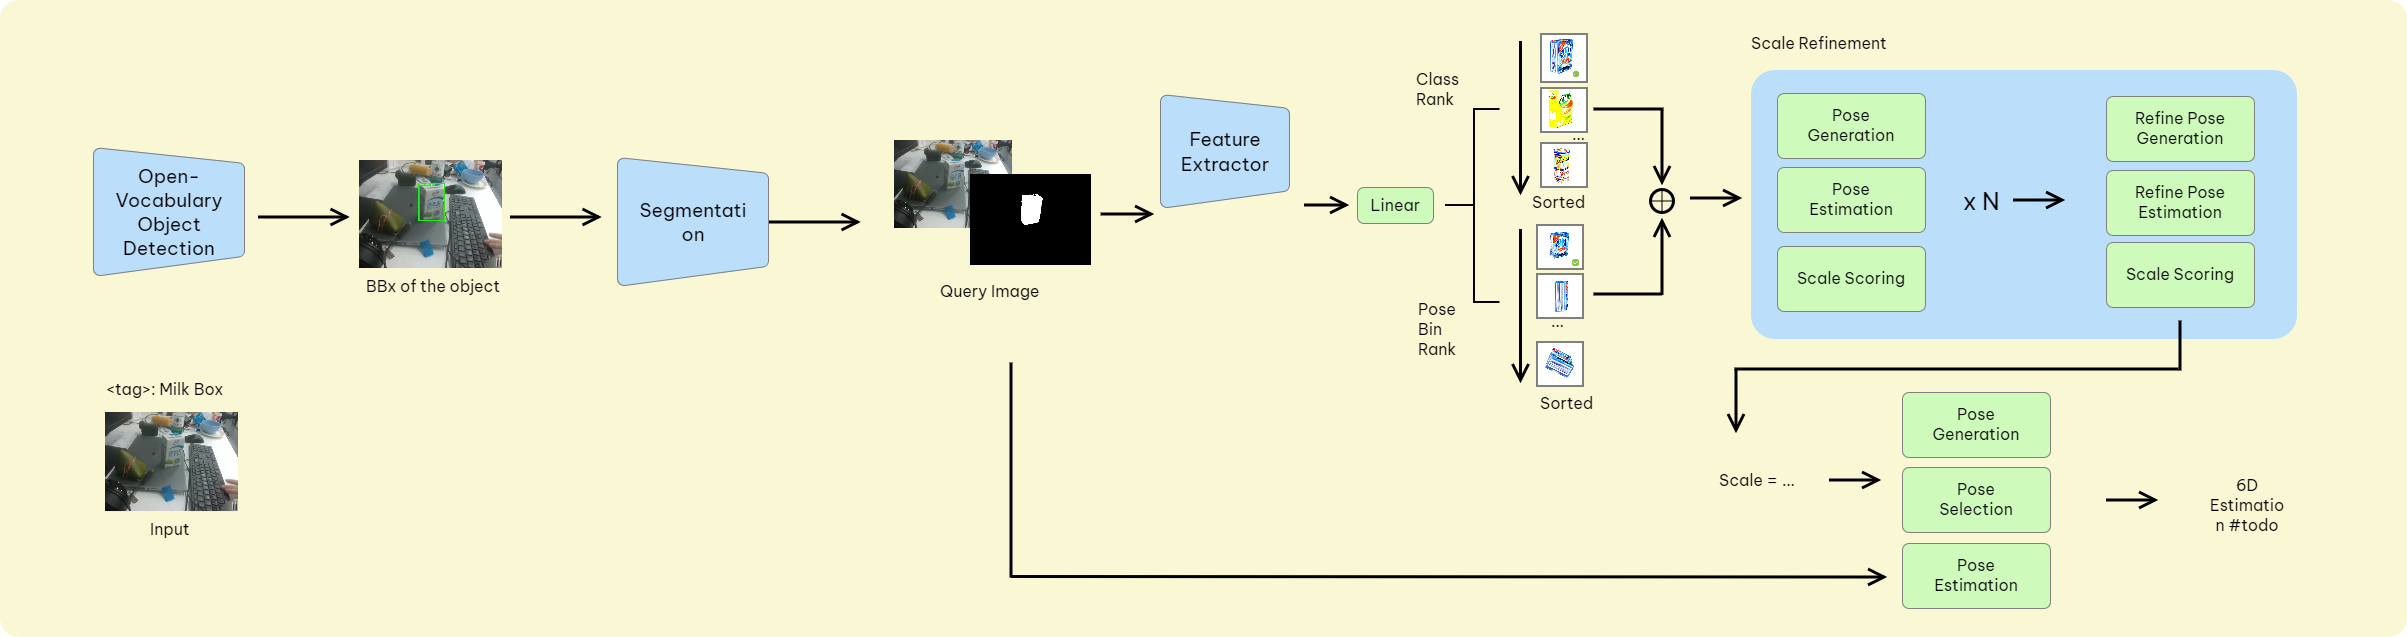
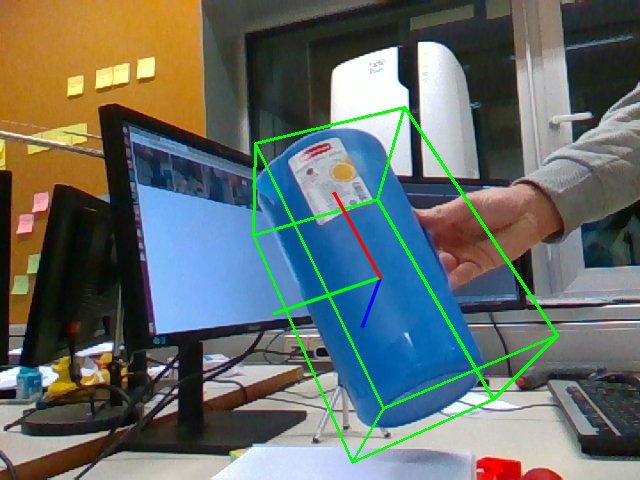
This work connects open-vocabulary detection and segmentation with object pose estimation for robotic manipulation.
Approach
I integrated GroundingDINO, SAM-HQ, DINOv3 and FoundationPose to support CAD-based and non-CAD object workflows, with synthetic data and geometry-processing tools supporting experiments.
Results & Current Status
An integrated perception pipeline developed during my 2025 Midea Group research placement, supported by a separate Blender synthetic-data toolchain.