Overview
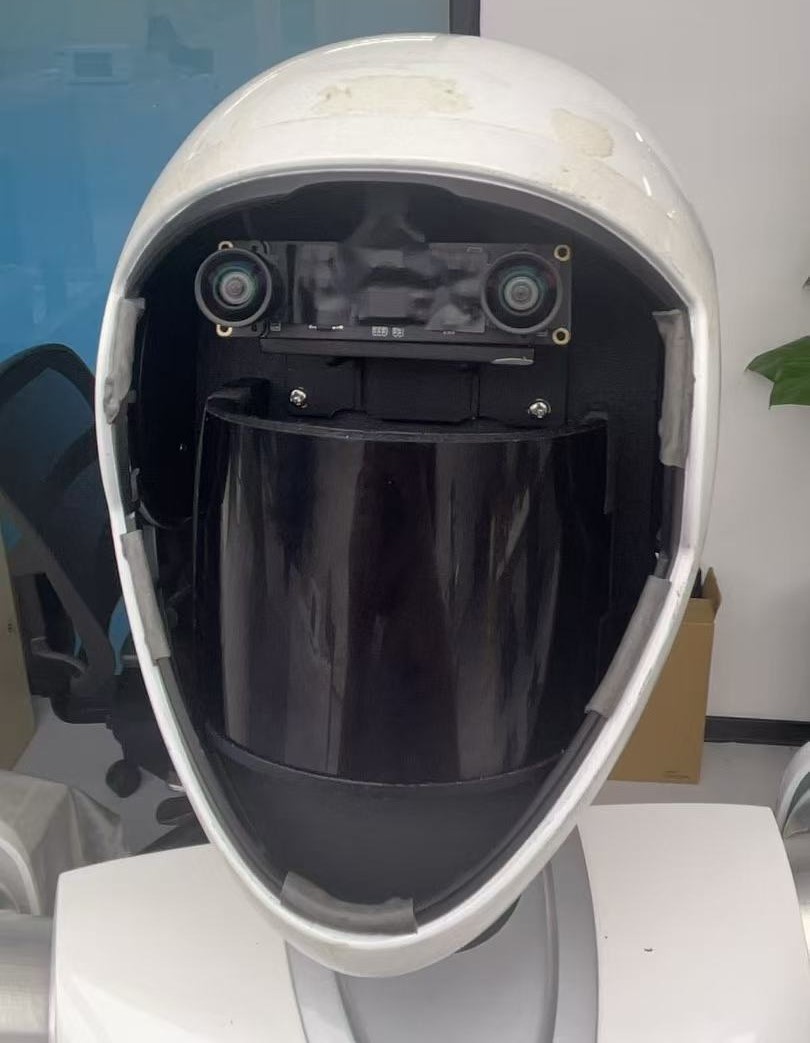
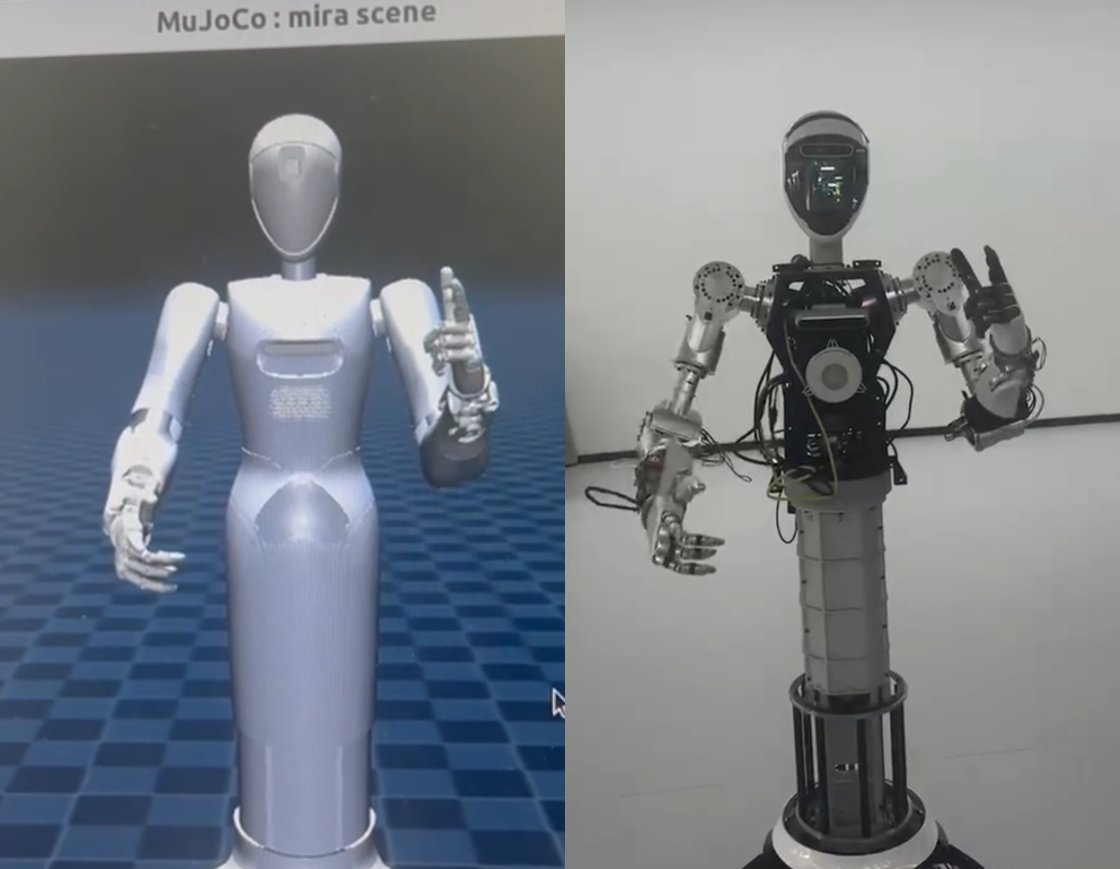
During my 2025 research placement at Midea Group, I developed mixed-reality teleoperation functionality for humanoid manipulation and demonstration collection.
Approach
The system combines spatial anchoring, hand/object tracking, bidirectional streaming and recording/playback, supporting manipulation experiments and reinforcement-learning data collection.
Results & Current Status
A teleoperation and demonstration-recording workflow developed alongside perception, control and visualization integration.