
Overview
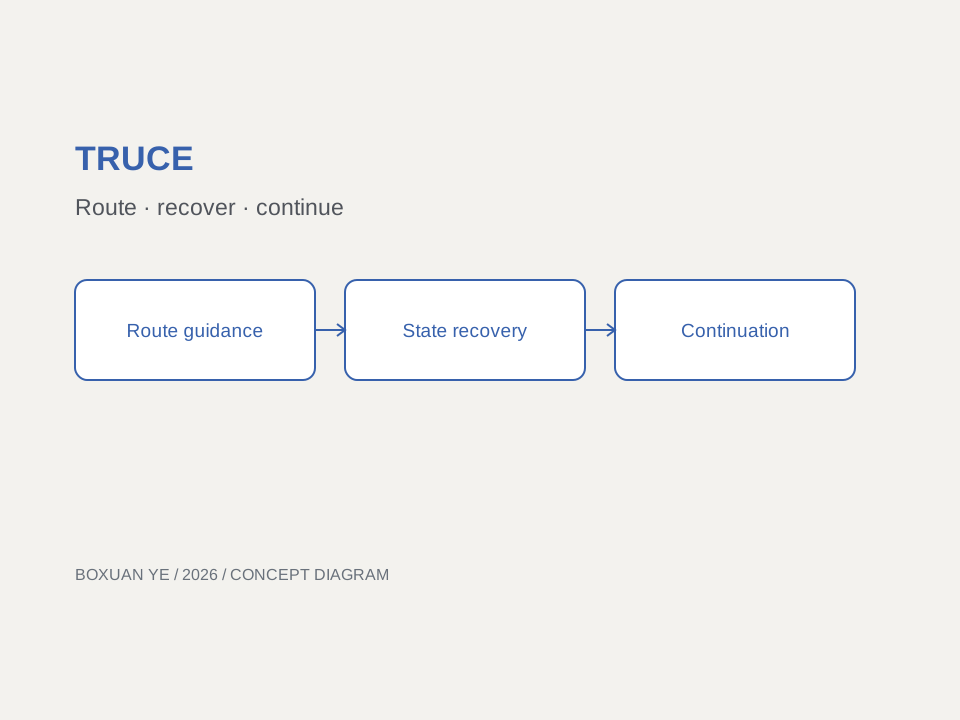
TRUCE studies how a quadrotor can keep making progress when a local planner becomes stuck or its reference diverges from the vehicle state. The framework works around existing planners and separates checks on the planned reference from checks on predicted vehicle motion.
Approach
The system combines persistent route guidance, recovery initialized from measured vehicle state, and predictive continuation checks. Polynomial references are checked using Bernstein bounds and subdivision. Integrations include EGO v1, EGO v2, MINCO and SANDO.
Results & Current Status
On 100 shared MetaUrban tasks with simulated quadrotor dynamics, TRUCE reached the goal in 83% of tasks with no recorded contacts, compared with 22% for official ROS EGO v1 and 26% for EGO v1 with Gatekeeper. A separate 240-run study increased aggregate goal reaching from 104/120 to 118/120 and reduced recorded contacts from eight to zero, at increased computation and travel time. These are simulation results, not a real-world safety guarantee. First-author manuscript with David Boyle, submitted to ICRA 2027.