Overview
This independent project integrates RGB-D perception and a six-degree-of-freedom robotic arm into an object-grasping pipeline.
Approach
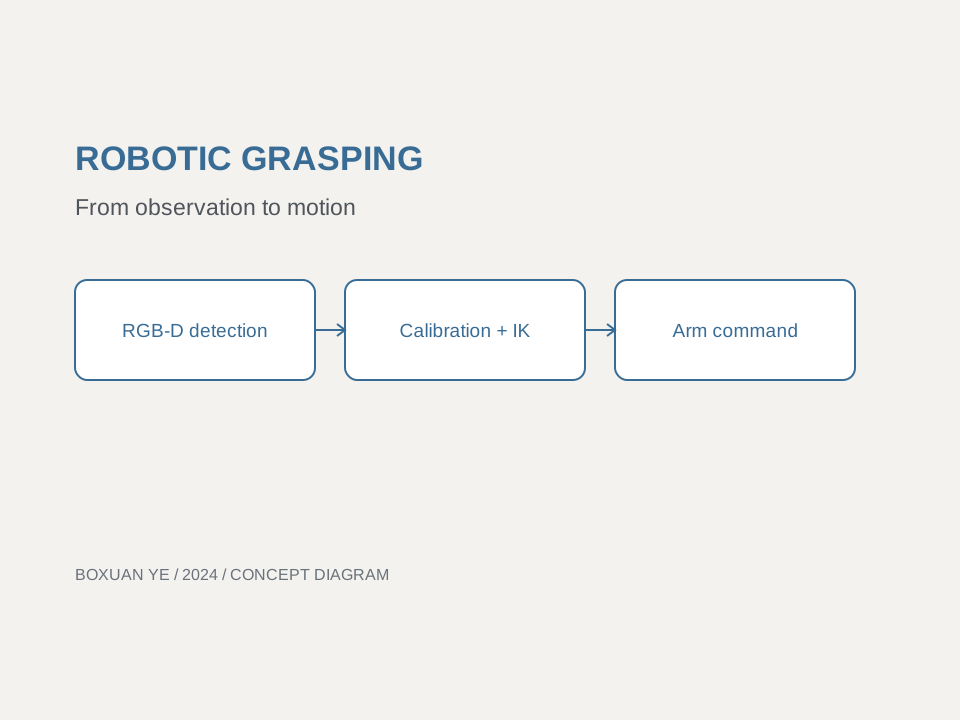
YOLOv8 detections and Intel RealSense RGB-D measurements provide object observations. Hand–eye calibration maps these measurements into the robot frame, while IKPy provides inverse-kinematics solutions and Python/UART handles arm commands.
Results & Current Status
An integrated perception-to-control grasping pipeline linking object detection, depth sensing, calibration, inverse kinematics and hardware communication.